Gaojing
Zhang
PhD student in embodied intelligence at the University of Sussex (CSC-funded), and visiting researcher at Shanghai Jiao Tong University · HIROL Lab. Building the bridge from language to low-level robot control. 具身智能 方向博士生,苏塞克斯大学(国家留学基金委资助),上海交通大学 HIROL 实验室访问研究员。致力于打通语言指令与底层机器人控制之间的桥梁。
Funny performer · Nature's recorder · Novice of embodied intelligence 有趣的表演者 · 自然的记录者 · 具身智能的新人

About关于我
I am a PhD student at the University of Sussex (funded by CSC), where I received my MSc in Robotics in June 2025. I conduct research on embodied intelligence in the Autonomous Intelligence & Robotic Embodiment Lab, supervised by Prof. Bao Kha Nguyen.
I am also a visiting doctoral student at the School of Artificial Intelligence, Shanghai Jiao Tong University (HIROL Lab), supervised by Prof. Lian Wenzhao. As a newcomer to embodied intelligence, I’m eager to learn from senior researchers and peers — if you’re interested in my work, please feel free to reach out.
我是英国苏塞克斯大学的博士生(由国家留学基金委资助),已于2025年6月获得该校机器人学硕士学位。目前在”自主智能与机器人具身实验室”从事具身智能相关研究,导师为 Bao Kha Nguyen 教授。
同时,我也是上海交通大学人工智能学院(HIROL 实验室)的访问博士生,导师为连文昭教授。作为具身智能领域的新人,我渴望向前辈和同行学习——如果你对我的研究感兴趣,欢迎随时联系我。
Research Orientation研究方向
Embodied AI & Multimodal Foundation Models 具身智能 & 多模态基础模型
// 01
Leveraging Large Vision-Language Models (LVLMs) for embodied reasoning and decision-making.
// 02
Instruction following and long-horizon planning in complex environments (VLN).
// 03
Parameter-efficient fine-tuning (PEFT) and alignment of foundation models for robotics tasks.
// 04
Bridging the gap between high-level linguistic instructions and low-level control policies.
// 05
Cross-modal representation learning for embodied agents in 3D environments.
// 01
利用大型视觉-语言模型(LVLM)进行具身推理与决策。
// 02
复杂环境下的指令跟随与长时程规划(视觉语言导航,VLN)。
// 03
面向机器人任务的基础模型参数高效微调(PEFT)与对齐。
// 04
弥合高层语言指令与底层控制策略之间的鸿沟。
// 05
面向具身智能体的三维环境跨模态表征学习。
Education & Experience教育经历 & 科研经历
2025.10 — Present
PhD Student
University of Sussex, UK
2023.09 — 2025.06
MSc in Robotics
University of Sussex, UK
2017.09 — 2021.06
BEng, Computer Science & Technology
Henan Normal University, China
2025.10 — 至今
博士研究生
英国苏塞克斯大学
2023.09 — 2025.06
机器人学硕士
英国苏塞克斯大学
2017.09 — 2021.06
计算机科学与技术学士
河南师范大学
2025.09 — Now
Visiting Student
SJTU · School of AI · HIROL Lab
2025.03 — 2025.09
Research Assistant
SJTU · School of AI · HIROL Lab
Embodied intelligence platform: hand-eye calibration, underlying interface programming for different robots, motion-capture system, object marking & data acquisition.
2025.09 — 至今
访问学生
上海交通大学 · 人工智能学院 · HIROL实验室
2025.03 — 2025.09
科研助理
上海交通大学 · 人工智能学院 · HIROL实验室
具身智能平台建设:手眼标定模块、多类型机器人底层接口编程、动作捕捉系统、物体标注与数据采集。
News最新动态
2026.02
One paper accepted by ICRA 2026 🎉
2025.06
Received funding from the China Scholarship Council (CSC) 🎉
2026.02
一篇论文被 ICRA 2026 录用 🎉
2025.06
获得国家留学基金委(CSC)资助 🎉
Publications论文发表
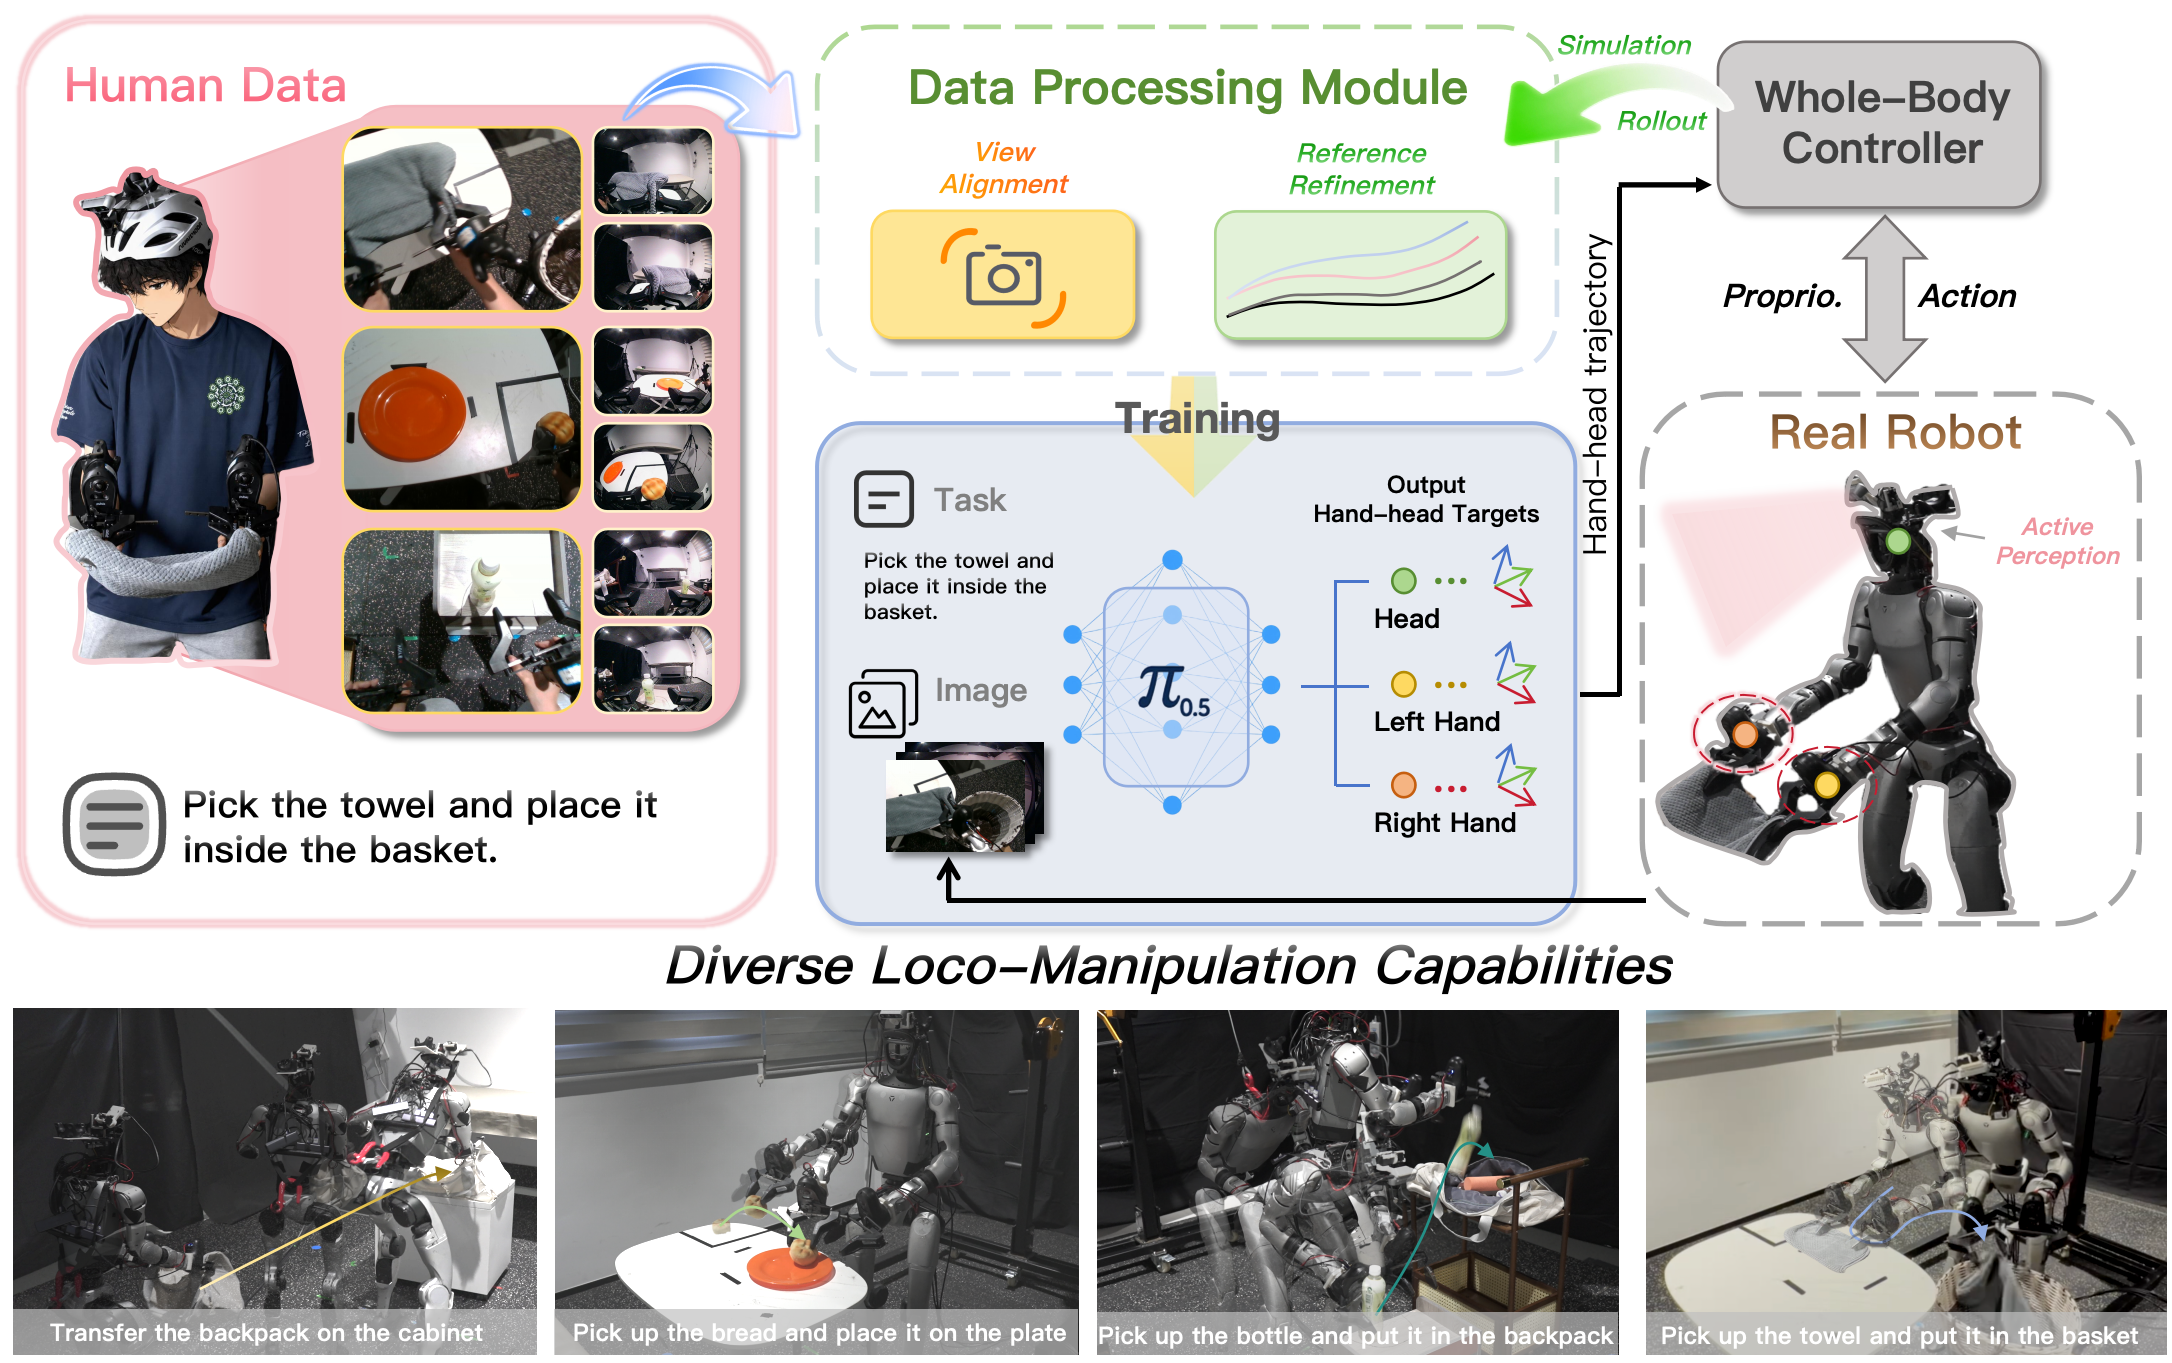
HALOMI: Learning Humanoid Loco-Manipulation with Active Perception from Human Demonstrations
A scalable framework that learns robust humanoid loco-manipulation from egocentric human demonstrations, combining active perception with precise head–hand trajectory tracking.
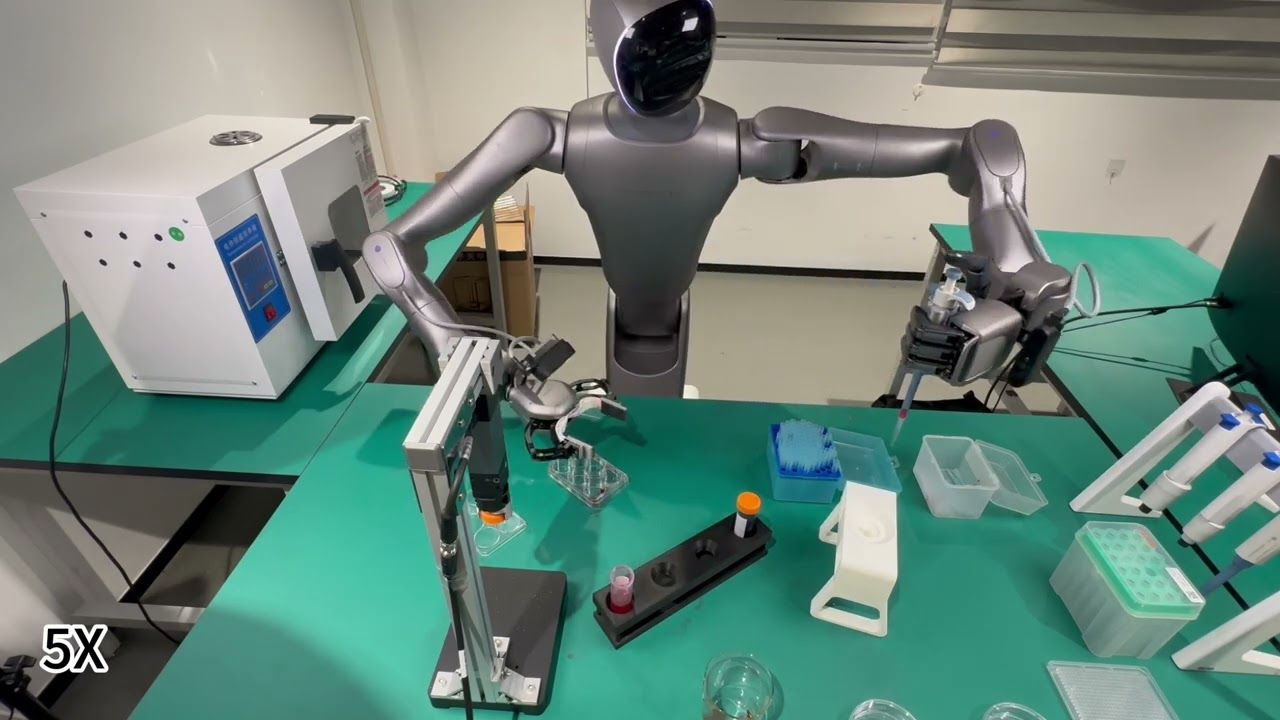
BioAgent: A Skill-Orchestrated Robot Agent for Biological Experiments
A skill-orchestrated robot agent for long-horizon biological experiments, integrating task planning, skill matching, execution, monitoring, and recovery into one workflow.

FSAG: Enhancing Human-to-Dexterous-Hand Finger-Specific Affordance Grounding via Diffusion Models
A data-efficient framework that bypasses robot grasp-data collection by exploiting the rich, object-centric semantic priors latent in pretrained generative diffusion models.

SAGE: Scene Graph-Aware Guidance and Execution for Long-Horizon Manipulation Tasks
A novel framework for scene graph-aware guidance and execution, targeting reliable long-horizon manipulation.

An unsupervised multi-view stereoscopic system based on Gaussian Splatting — Low-Light Gaussian Splatting — for reconstruction in near-total darkness.

Meta-Scoop: A Coarse-to-Precise Policy Learning Framework for Precision Scooping Across Task Variations
A coarse-to-precise framework enabling precise scooping operations across diverse task variations.
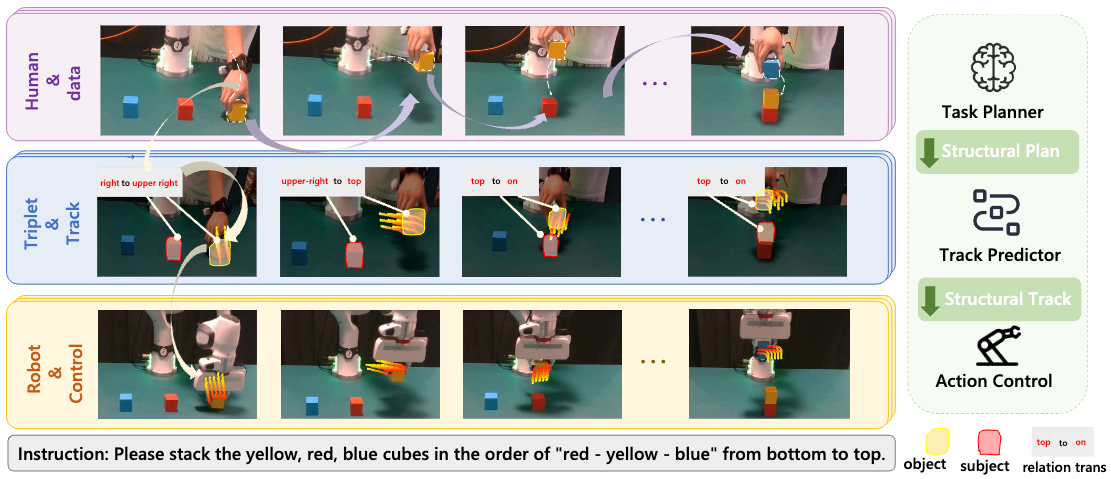
Triplet2Track: A Hierarchical System with Object-Centric Representations for Reliable Long-Horizon Manipulation
The Triplet-to-Track System (TTS): a closed-loop long-horizon imitation-learning system that uses human videos to reduce reliance on robot-collected data.
HALOMI: Learning Humanoid Loco-Manipulation with Active Perception from Human Demonstrations
提出一种可扩展框架,通过第一视角人类示范学习稳健的人形机器人移动操作能力,并结合主动感知与精确的头部—双手轨迹跟踪。
FSAG: Enhancing Human-to-Dexterous-Hand Finger-Specific Affordance Grounding via Diffusion Models
提出一种数据高效框架,利用预训练生成式扩散模型中蕴含的丰富、以物体为中心的语义先验,从而绕过机器人抓取数据的采集过程。
SAGE: Scene Graph-Aware Guidance and Execution for Long-Horizon Manipulation Tasks
提出 SAGE——一种面向长时程操作任务、具备场景图感知能力的引导与执行新框架。
提出一种基于高斯泼溅(Gaussian Splatting)的无监督多视角立体视觉系统——低光高斯泼溅,用于纯黑暗环境下的图像增强与重建。
Meta-Scoop: A Coarse-to-Precise Policy Learning Framework for Precision Scooping Across Task Variations
提出一种由粗到精的策略学习框架,在多种任务变化下实现精确的舀取操作。
Triplet2Track: A Hierarchical System with Object-Centric Representations for Reliable Long-Horizon Manipulation
提出 Triplet-to-Track 系统(TTS)——一种闭环长时程模仿学习系统,利用人类视频演示降低对机器人采集数据的依赖。

Using a Franka arm to complete the tangram puzzle.

A dual-arm robot (Monte) completing pick-and-place via GraspNet.

Using a VLM to make the decision: should we suck or grab?
BioAgent orchestrates long-horizon biological experiments through task planning, skill matching, execution, monitoring, and recovery.
使用 Franka 机械臂完成七巧板拼图任务。
使用双臂机器人 Monte,通过 GraspNet 完成抓取放置任务。
利用视觉语言模型(VLM)进行决策:该吸取还是抓取?
Honors & Awards荣誉与奖项
2025
CSC Government Scholarship for Doctoral Studies Abroad
2025 · Top 1%
Sussex University Dean’s Scholarship
2025 · Top 5%
Sussex University International Doctoral Scholarship
Reviewer for
ICRA 2026
ICME 2026
2025
国家留学基金委公派出国攻读博士学位奖学金
2025 · 前1%
苏塞克斯大学院长奖学金
2025 · 前5%
苏塞克斯大学国际博士奖学金
担任审稿人
ICRA 2026
ICME 2026
Let's build embodied intelligence together. 一起探索具身智能的未来。
Interested in my work, or thinking about collaboration? I'd love to hear from you. 如果你对我的研究感兴趣,或想探讨合作机会,欢迎随时与我联系。